Nanjing University · SOARLAB
Hao Xu 徐浩
Tenure-track Associate Professor
School of Intelligence Science and Technology, Nanjing University
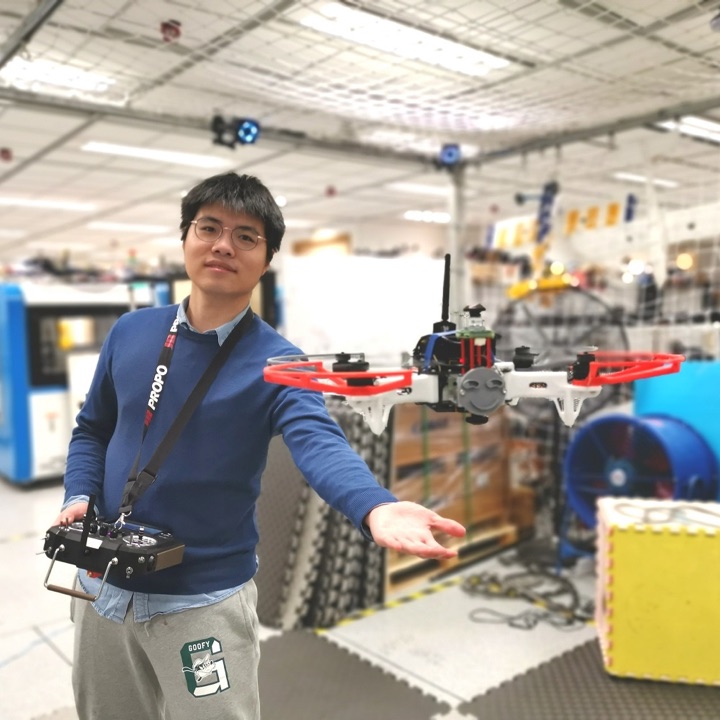
I am a tenure-track associate professor at the School of Intelligence Science and Technology, Nanjing University, where I lead SOARLAB, the Flying General Intelligence Lab. My research centers on embodied AI for drones, humanoids, and flying humanoids.
Before NJU, I was an associate researcher at Beihang University and a multi-sensor fusion algorithm engineer at DJI, where I worked on the SLAM 2/3 localization algorithms used in the DJI Air 3S. I received my Ph.D. in Electronic and Computer Engineering from HKUST in 2023, advised by Prof. Shaojie Shen, and my B.Sc. in Physics from the University of Science and Technology of China.
 Join SOARLAB
Recruiting Ph.D. and master's students for 2027 →
News
-
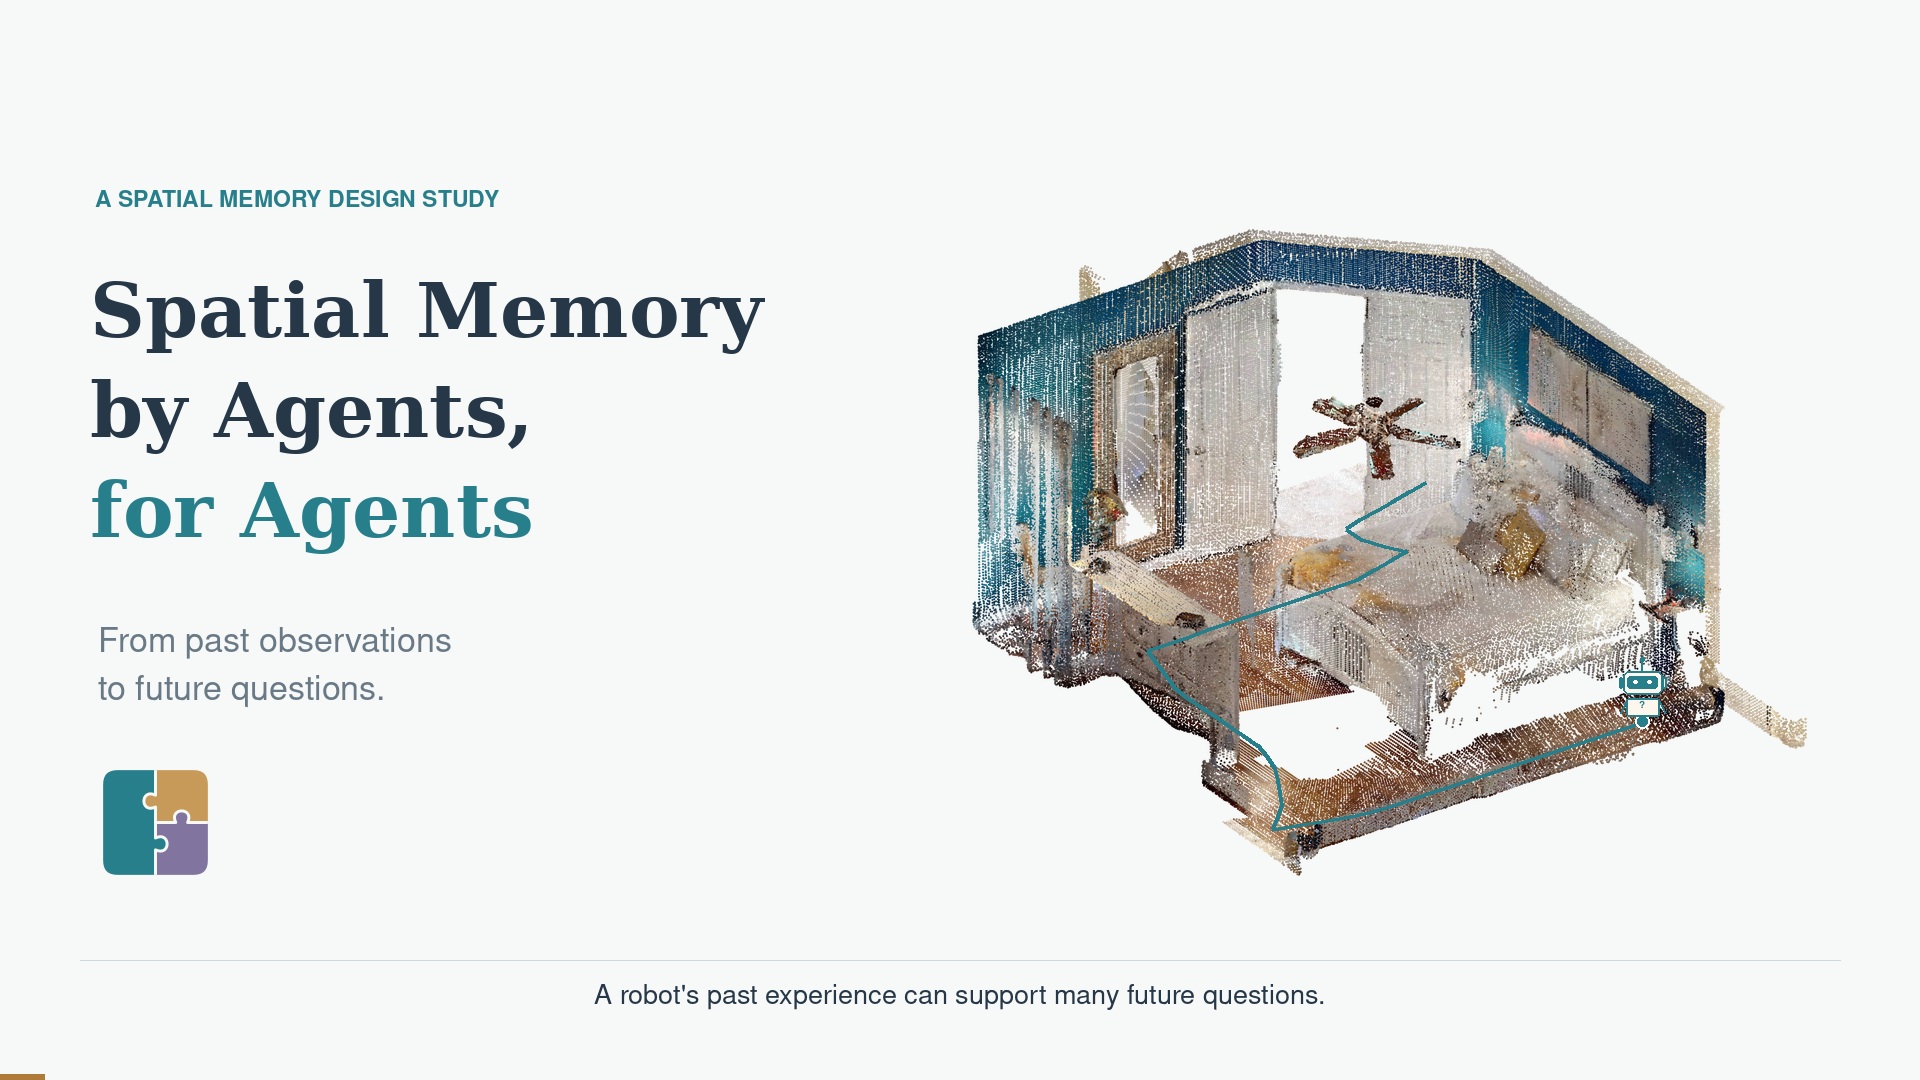
New preprint Spatial Memory by Agents, for Agents: coding agents design a robot's spatial memory by writing code, running benchmarks, and iterating on feedback, which we call Guided System Improvement (GSI). The best configuration improves the average unified score by about 51% over the strongest all-task baseline. With Mondo Robotics. Project page
-
AUG received an Honorable Mention for the IROS 2026 Best Paper Award on Safety, Security, and Rescue Robotics.
-
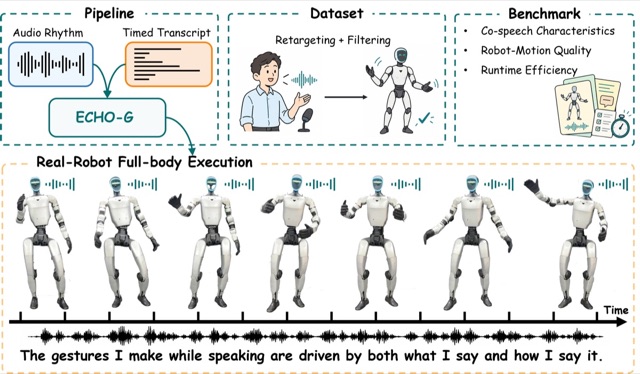
ECHO-G is out: humanoids that gesture on the beat while they talk, with end-to-end whole-body control running on a Jetson Orin AGX. With Mondo Robotics and the HKUST Aerial Robotics Group. arXiv · Code · Video
-
Started SOARLAB, the Flying General Intelligence Lab, at Nanjing University. We are recruiting Ph.D. and master's students for 2027: admissions.
Research
I work on embodied intelligence for robots that fly, walk, and work together: robotics agents that perceive, plan, and act on real hardware; world-action and vision-language-action foundation models for drones, humanoids, and flying humanoids; and the state estimation, SLAM, and swarm systems underneath them.
- Embodied AI
- Robotics agents
- WAM / VLA robot foundation models
- Flying humanoids
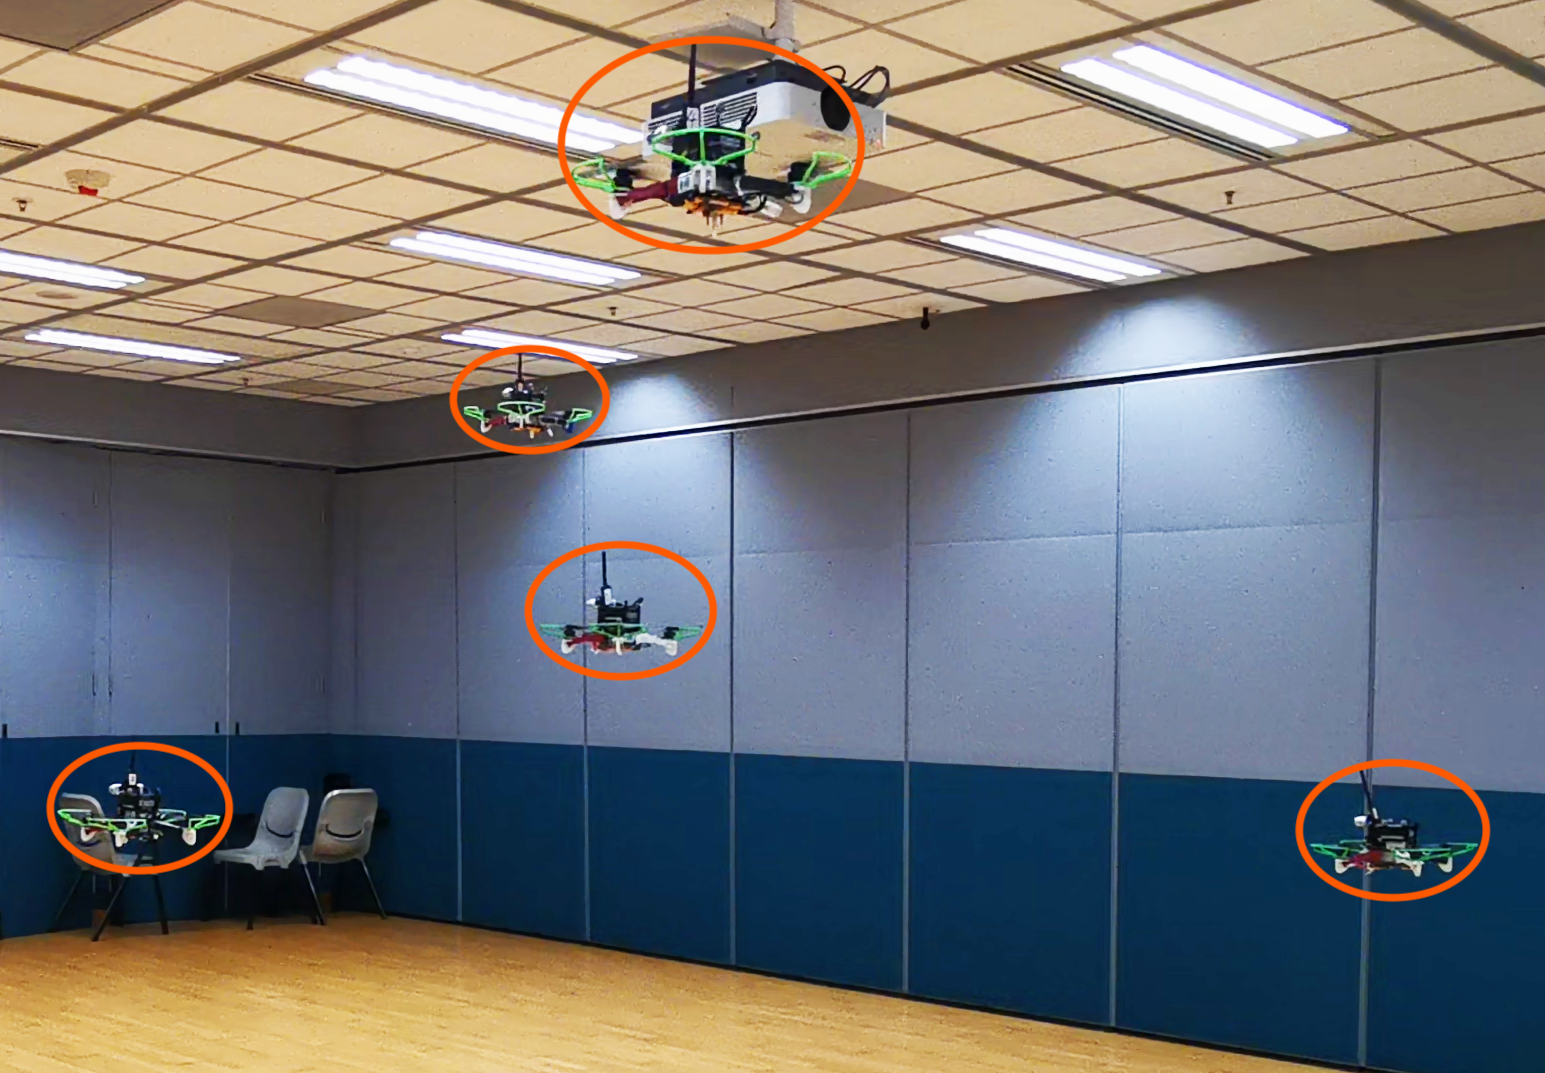
- Aerial swarms
- State estimation & SLAM
- Sensor fusion
Selected Publications
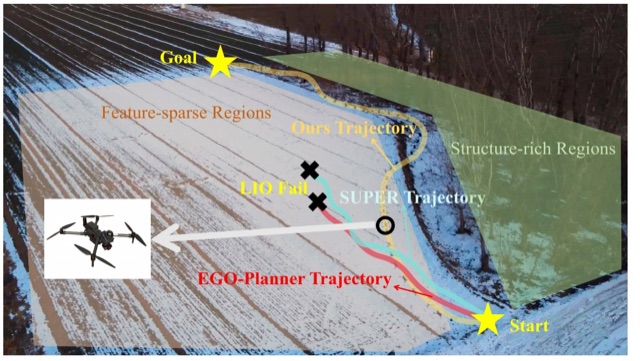
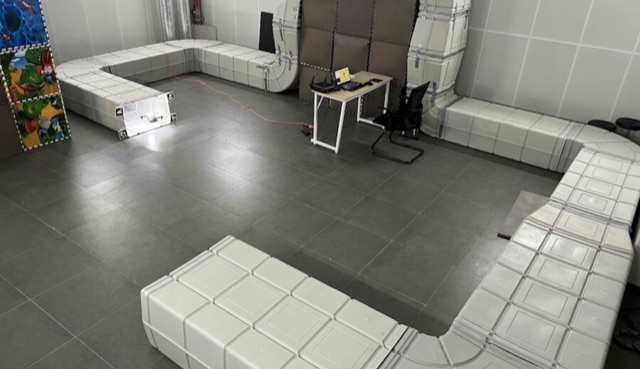
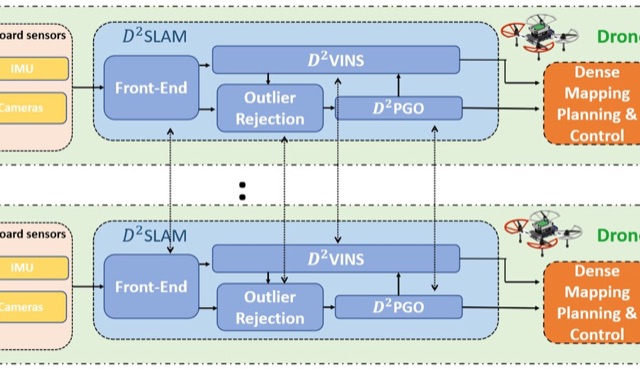
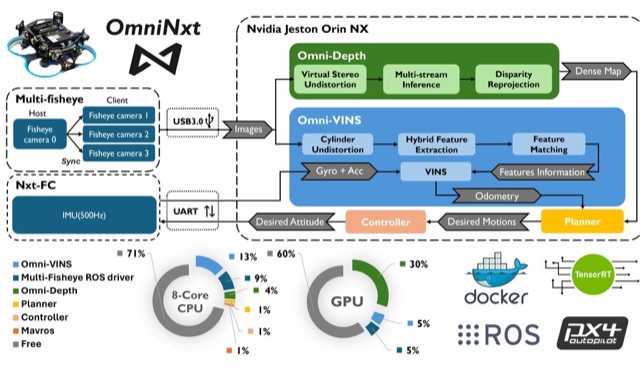
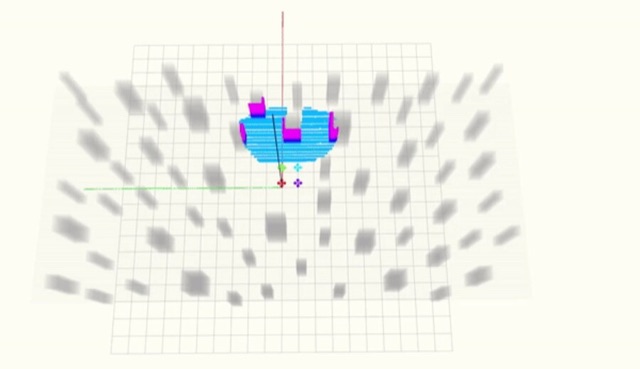
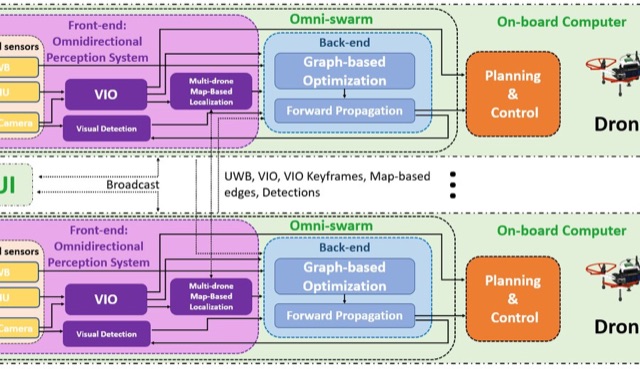
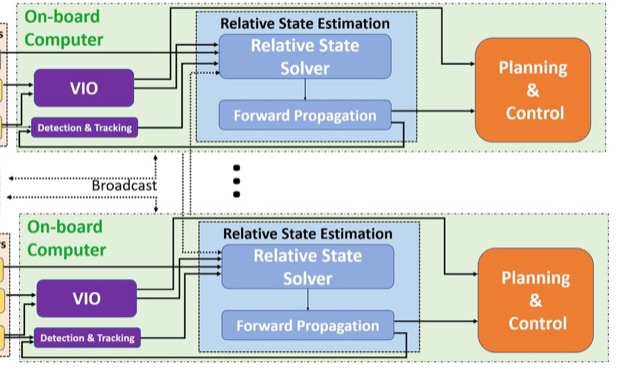
Full list on Google Scholar. * Equal contribution.
Open Source
- D²SLAM Decentralized and distributed collaborative visual-inertial SLAM for aerial swarms.
- Omni-Swarm Omnidirectional visual-inertial-UWB state estimation for aerial swarms.
- ECHO-G Co-speech whole-body gesture generation for humanoid robots.
- VINS-Fisheye Fisheye version of VINS-Fusion.
- FOXTracker Webcam head tracker for flight simulators, a TrackIR alternative.
- pyAircraftIden Aircraft system identification in Python.
Play
Beyond the Lab
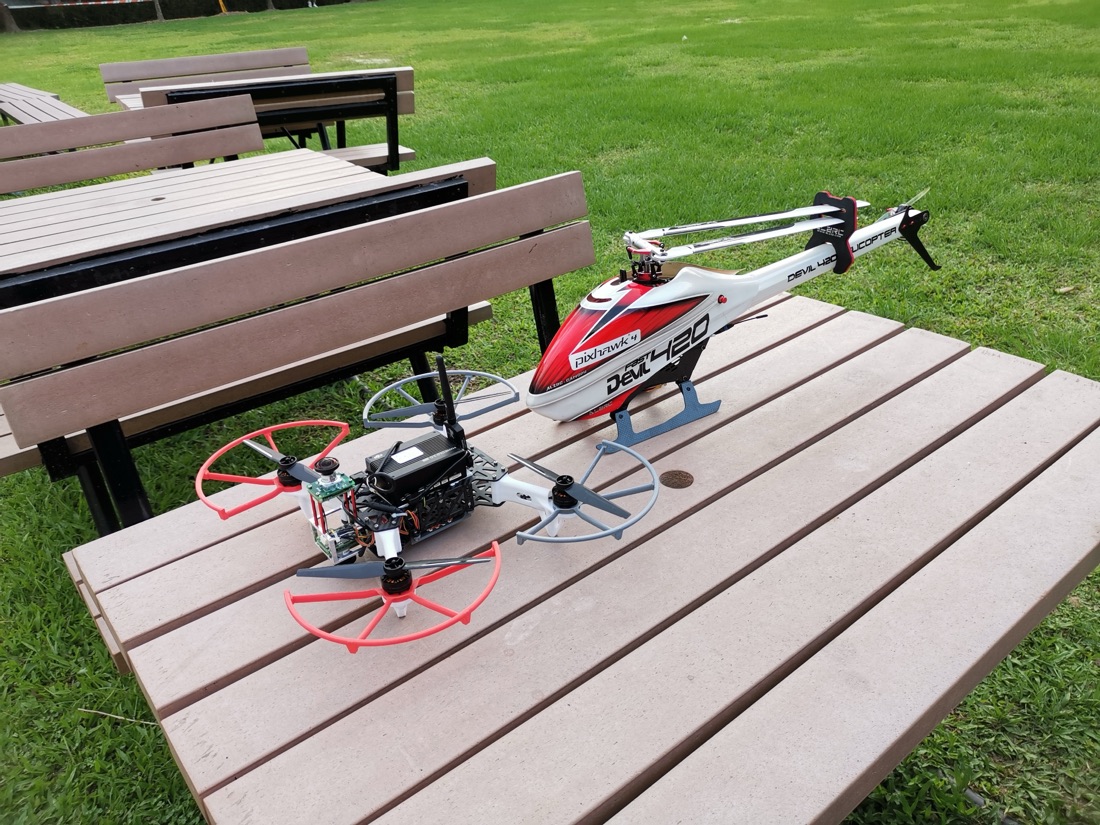
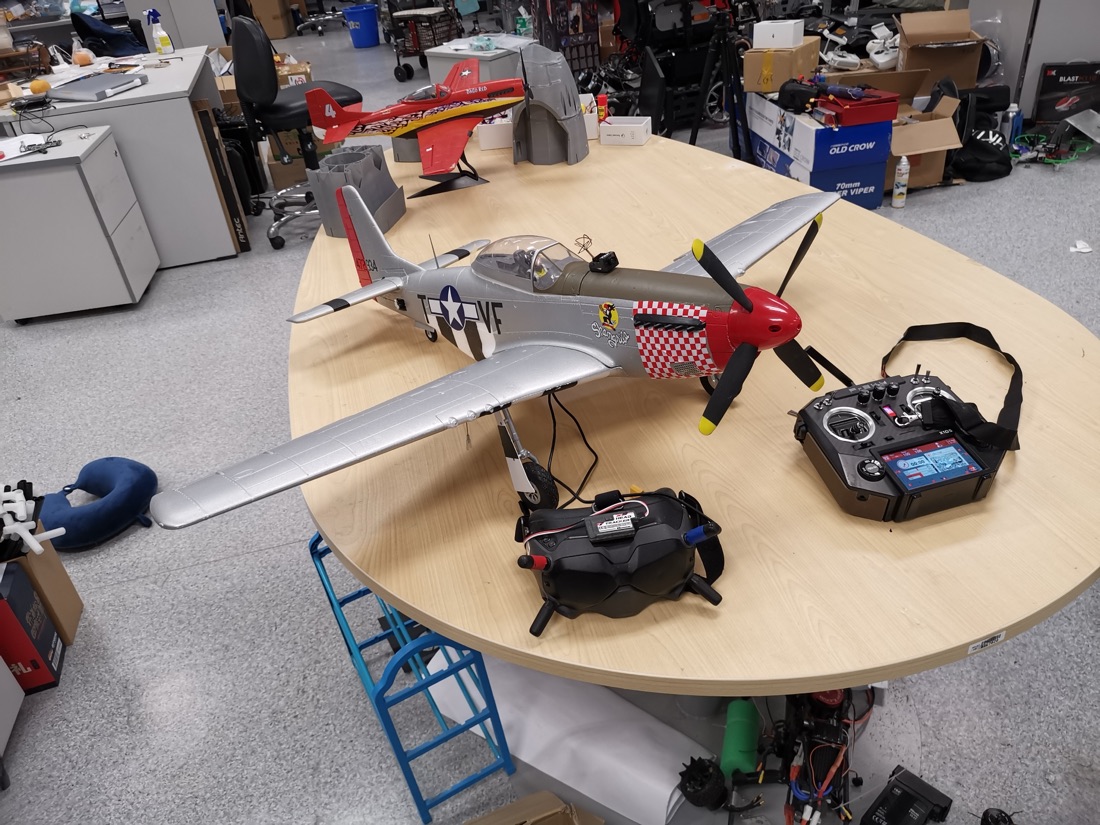
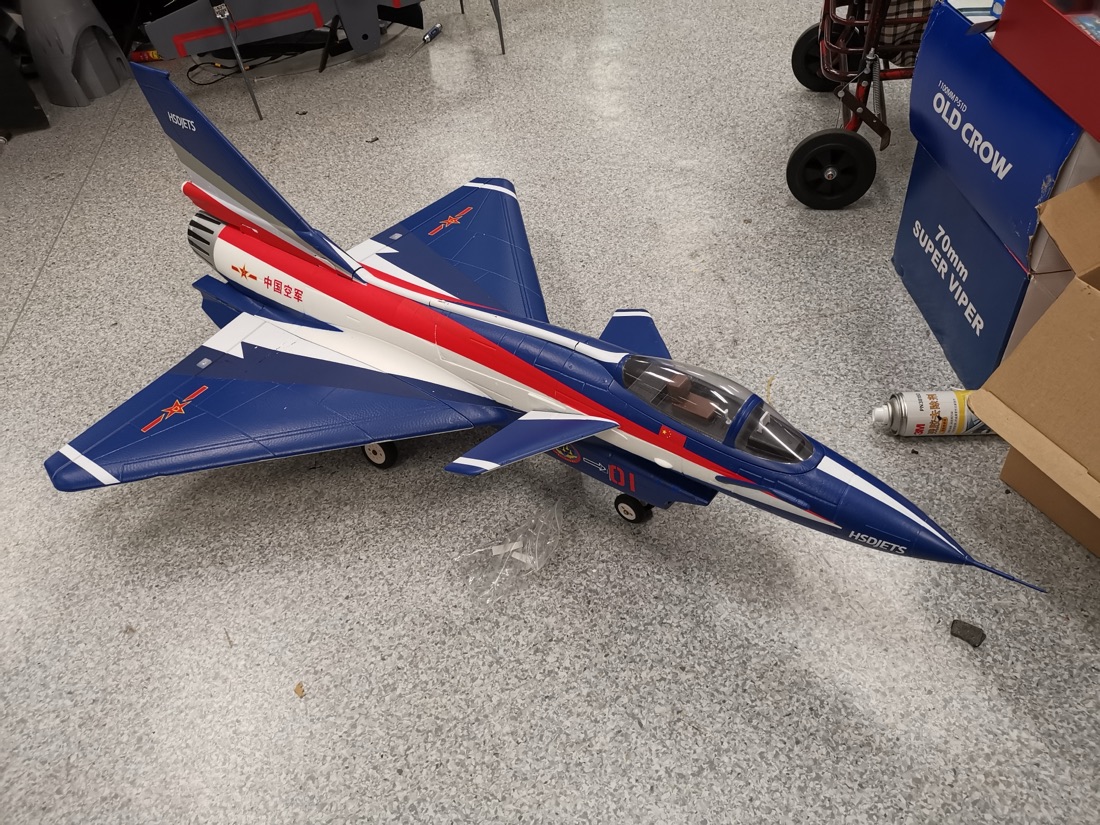
I have flown RC aircraft for years: helicopters, fixed-wing warbirds, jets, and FPV racing drones. I also build tools for flight simulation, such as FOXTracker and DCSNoJoy for DCS World.